Motion control specialist PI has released the new H-855 high-load hexapod robot family, a new modular 6-DOF positioning platform designed to precisely position and align payloads weighing up to 500 kg (1100 lbs).
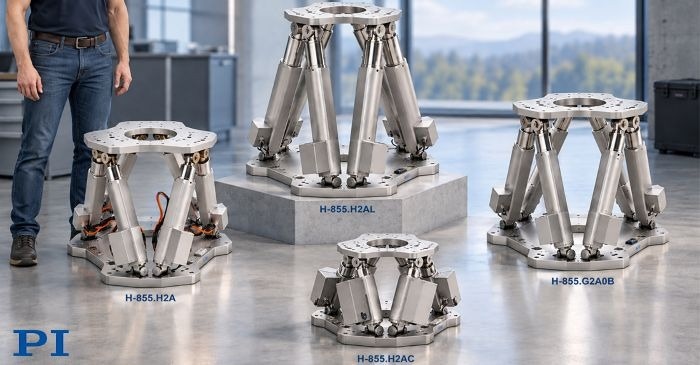 H-855 high-load hexapod micro-positioning system family. Image Credit: PI (Physik Instrumente) LP
Designed for multi-axis micropositioning tasks in industrial automation, optics, semiconductor, aerospace, and simulation applications, the H-855 precision positioning platform combines high load capacity with six-axis precision motion in a compact parallel-kinematic design. Four standard configurations allow customers to select a system optimized for precision and load capacity, speed, compact dimensions, or extended travel.
Four Configurations for Different Motion Requirements
Rather than using one mechanical configuration for every application, the H-855 family uses a modular architecture that allows the mechanics to be adapted to different performance requirements.
- The H-855.H2A precision positioning platform is optimized for accurately moving heavy components and supports payloads up to 500 kg (1100 lbs) when mounted with the base plate horizontal. Typical minimum incremental motion is 0.3 µm in X and Y and 0.15 µm in Z, with typical unidirectional repeatability of 0.4 µm in X and Y and 0.15 µm in Z.
- The H-855.G2A0B variant focuses on higher-throughput applications, with velocities up to 10 mm/s and features an integrated holding brake.
- The H-855.H2AC uses folded actuator legs and smaller platforms to reduce the required installation space.
- Lastly, the H-855.H2AL is designed for applications requiring extended motion ranges.
Depending on configuration, translational travel extends to 320 mm in X and Y and 150 mm in Z, while rotational motion extends to 120 ° in θZ.
Parallel Kinematics for Heavy Loads
Unlike stacked serial positioning systems, a hexapod controls all six degrees of freedom using six coordinated actuators operating between a common base and moving platform.
The parallel structure distributes loads through the complete mechanism while providing high stiffness and a favorable load-capacity-to-size, and weight ratio. It also avoids the accumulation of errors associated with stacking individual motion axes. Another advantage is the lack of dragged cables, as is common with traditional multi-axis serial kinematic motion systems.
Self-Locking Design Holds 1100 lbs Without Power
H-855 hexapods cannot only move heavy loads, they also hold the loads without power. The H-855.H2A variant is self-locking up to 500 kg (1100 lbs), without the need for brakes.
Absolute Encoders, Brushless Motors, Optional Brakes
The H-855 hexapod actuators are based on brushless DC gear motors with absolute rotary encoders. Absolute position information is available immediately after power-up, eliminating the need for a referencing or homing move before operation. This can simplify startup and integration in automated equipment. A motor brake is optional.
Easy Modifications Possible
The modular architecture allows actuator configurations, gear ratios, travel ranges, and geometries to be adapted within the same platform. This gives PI design engineers the ability to balance parameters, such as velocity, installation space, travel, holding force, and payload for a particular application, and develop custom hexapod variants for application-specific requirements.
Dedicated Parallel-Kinematics Hexapod Motion Controller
The H-855 high-load hexapod family is controlled by PI's C-887 series 3rd generation hexapod motion controller, which calculates the inverse kinematics required to translate Cartesian position commands into coordinated actuator motion. User-defined work and tool coordinate systems are supported, and the center of rotation can be freely defined in space. Depending on the controller version, interfaces include TCP/IP, RS-232, analog I/O, and EtherCAT.
H-855 High-Load Hexapod Family at a Glance
- Payload capacity and self-locking capability up to 500 kg
- Six-axis motion: X, Y, Z, θX, θY, θZ
- X/Y travel up to 320 mm
- Z travel up to 150 mm
- θZ rotation up to 120 °
- Maximum velocity up to 10 mm/s
- Minimum incremental motion down to 0.15 µm
- Absolute rotary encoders eliminate homing at startup
- Brushless DC gear motors
- Integrated holding brake on the high-speed H-855.G2A0B
- Modular architecture with application-specific configurations
- Operated by PI’s 3rd generation hexapod motion controller series
The H-855 parallel robotic family expands PI's hexapod technology into applications requiring precise multi-axis positioning of significantly heavier payloads, while providing engineers with several mechanical configurations instead of forcing load capacity, speed, travel, and installation size into a single design.
Applications and Industries Served
Industrial automation, aerospace, optics, semiconductor, satellite antenna test, and simulation applications